01
Cross-View Geometric Uncertainty
Predicts whether pose and depth induce geometrically consistent correspondences across consecutive views, guiding dense-point filtering and local translation optimization.
Streaming geometric foundation models are emerging as a compelling alternative to SLAM systems. Yet this streaming nature introduces a fundamental issue: each prediction is made from limited context, which is vulnerable to dynamic objects and weak textures. Small local errors accumulate into severe geometric distortion and long-horizon scale drift. We argue that reliable streaming reconstruction requires geometric foundation models to be not only predictive, but also self-correcting.
We introduce SURE-Map, a self-correcting framework built upon two complementary principles. First, we explicitly model cross-view geometric uncertainty, which measures whether jointly predicted pose and depth induce geometrically consistent cross-view pixel correspondences. Second, multi-timescale self-correction combines efficient consecutive-frame inference with sparse keyframe-window inference, periodically recalibrating the scale of recent trajectories using longer-range geometric evidence.
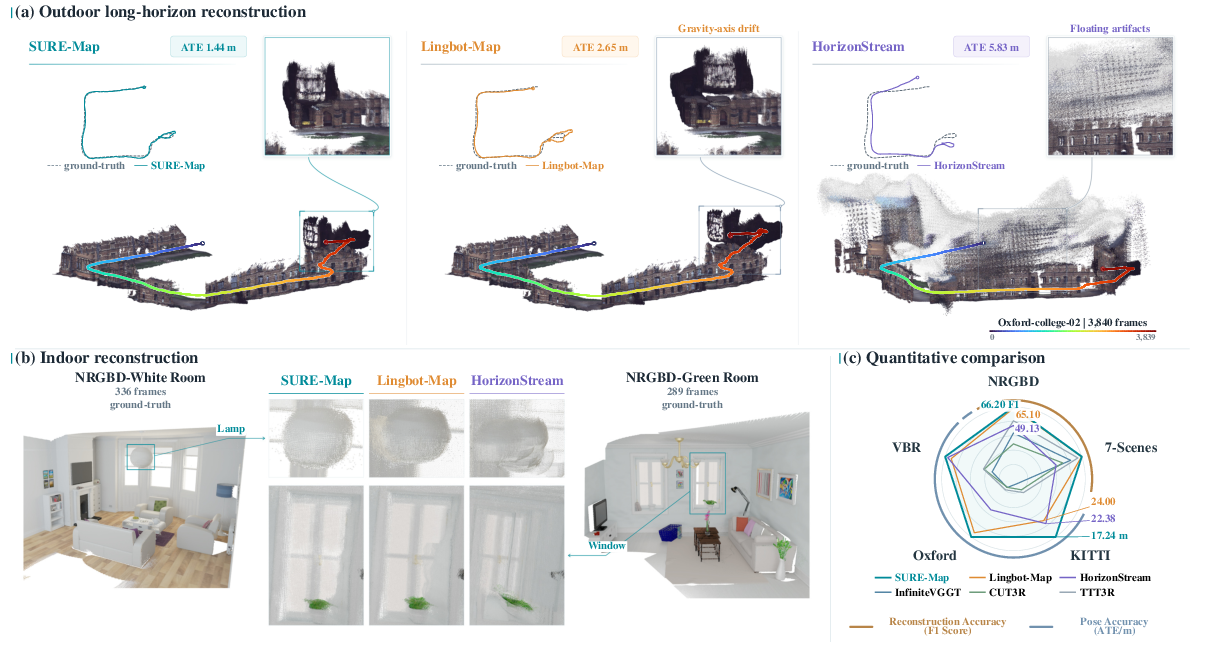
SURE-Map establishes new state-of-the-art performance for online feed-forward reconstruction across long-horizon benchmarks, reducing ATE-RMSE from 24.00 to 17.24 m on KITTI, 5.11 to 4.74 m on Oxford Spires, and 31.37 to 28.58 m on VBR, with further improvements to 15.17, 4.63, and 22.12 m when incorporating loop-closure refinement.
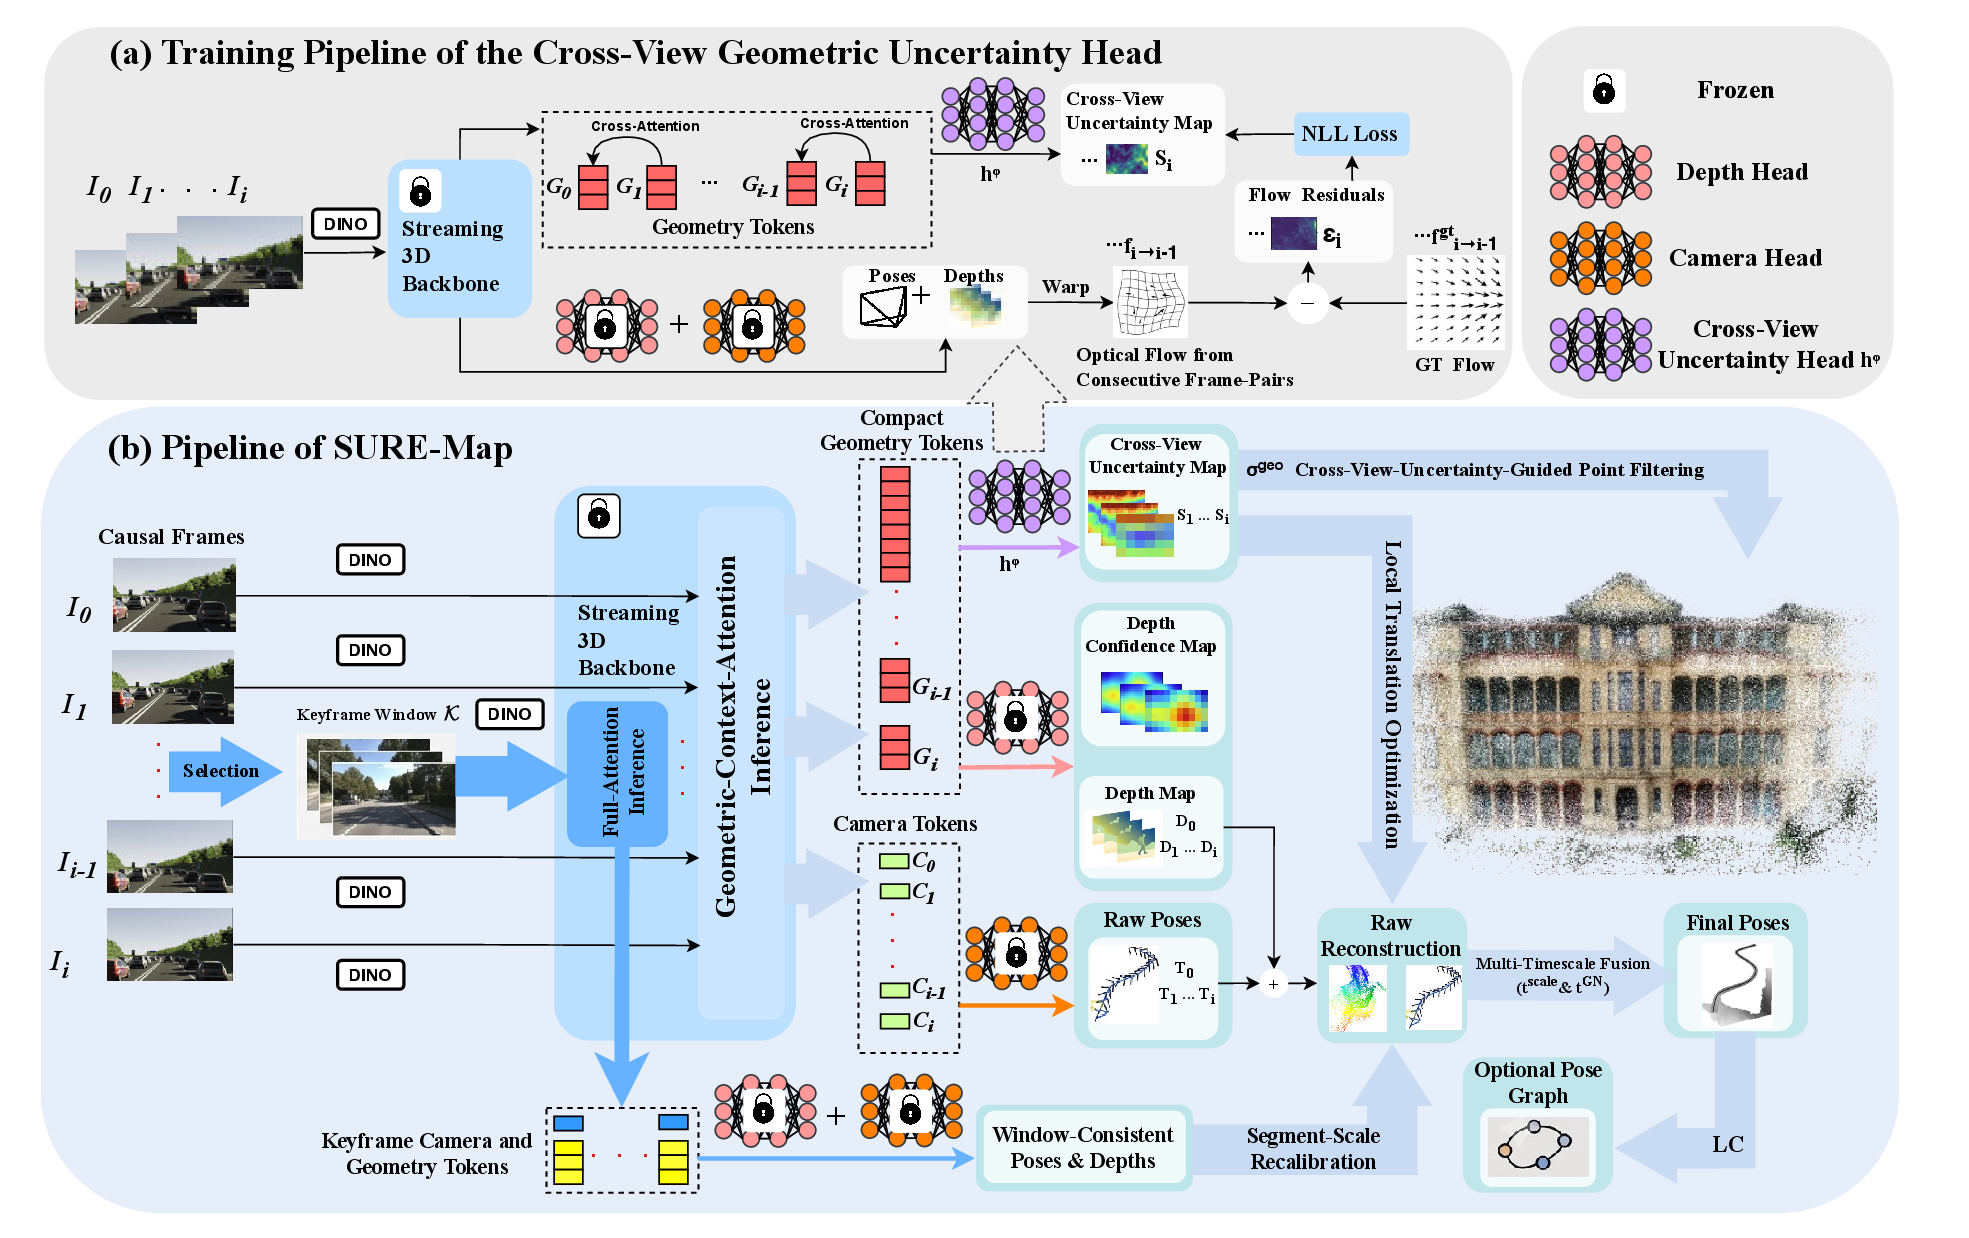
Predicts whether pose and depth induce geometrically consistent correspondences across consecutive views, guiding dense-point filtering and local translation optimization.
Couples fast causal updates with sparse full-attention keyframe-window inference to periodically recalibrate scale and suppress long-horizon drift.
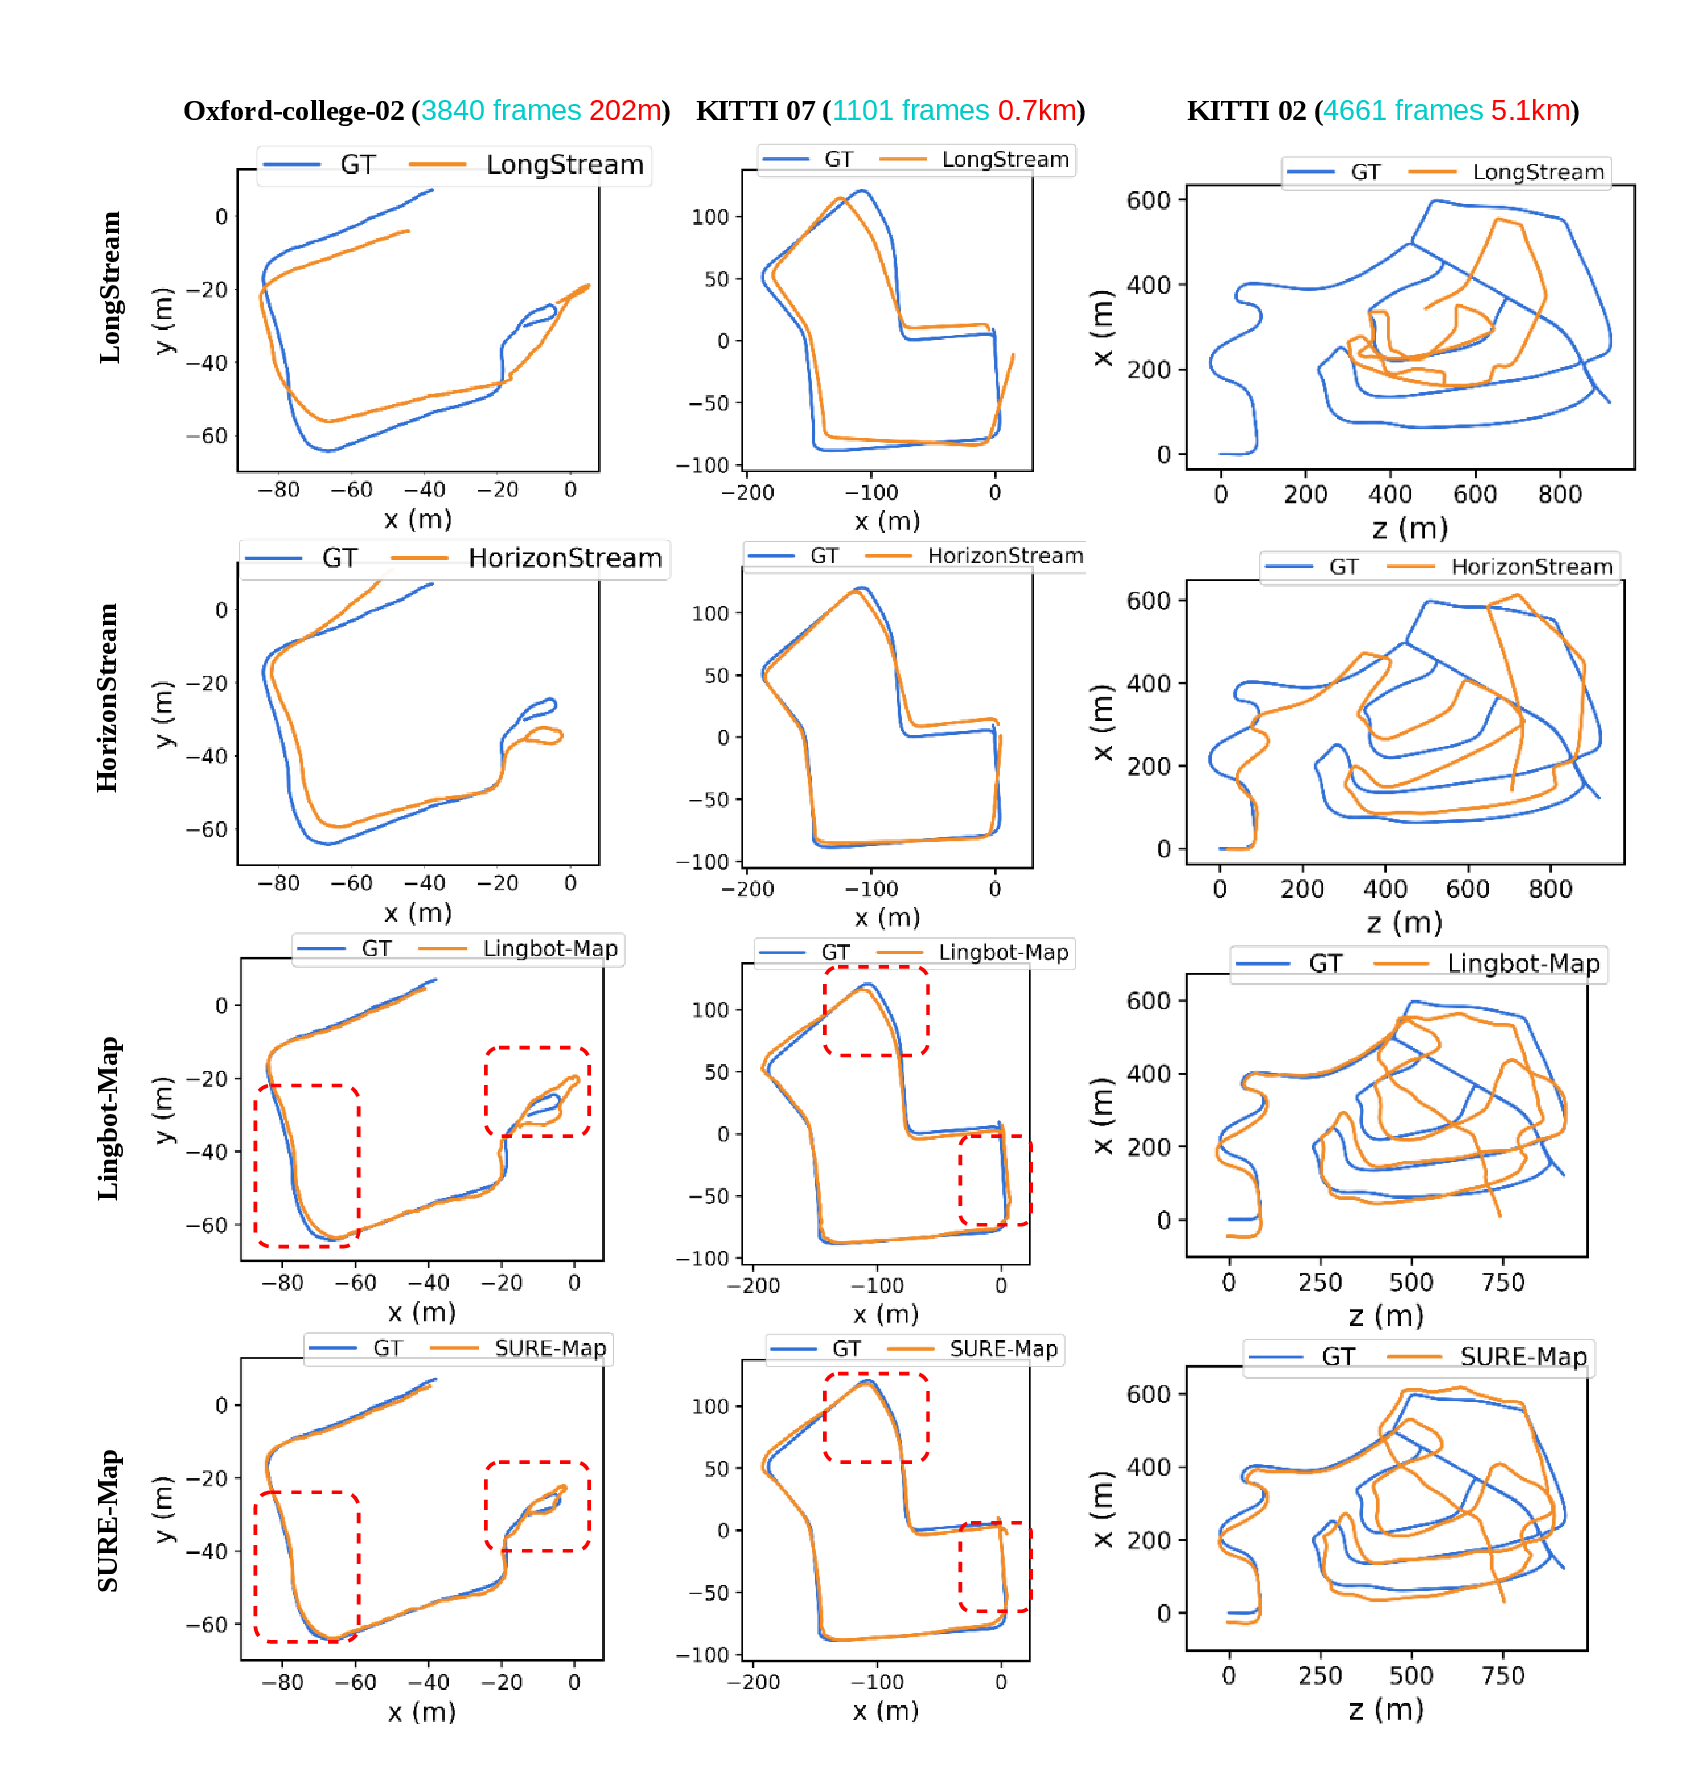
SURE-Map better preserves global trajectory shape across long outdoor sequences.
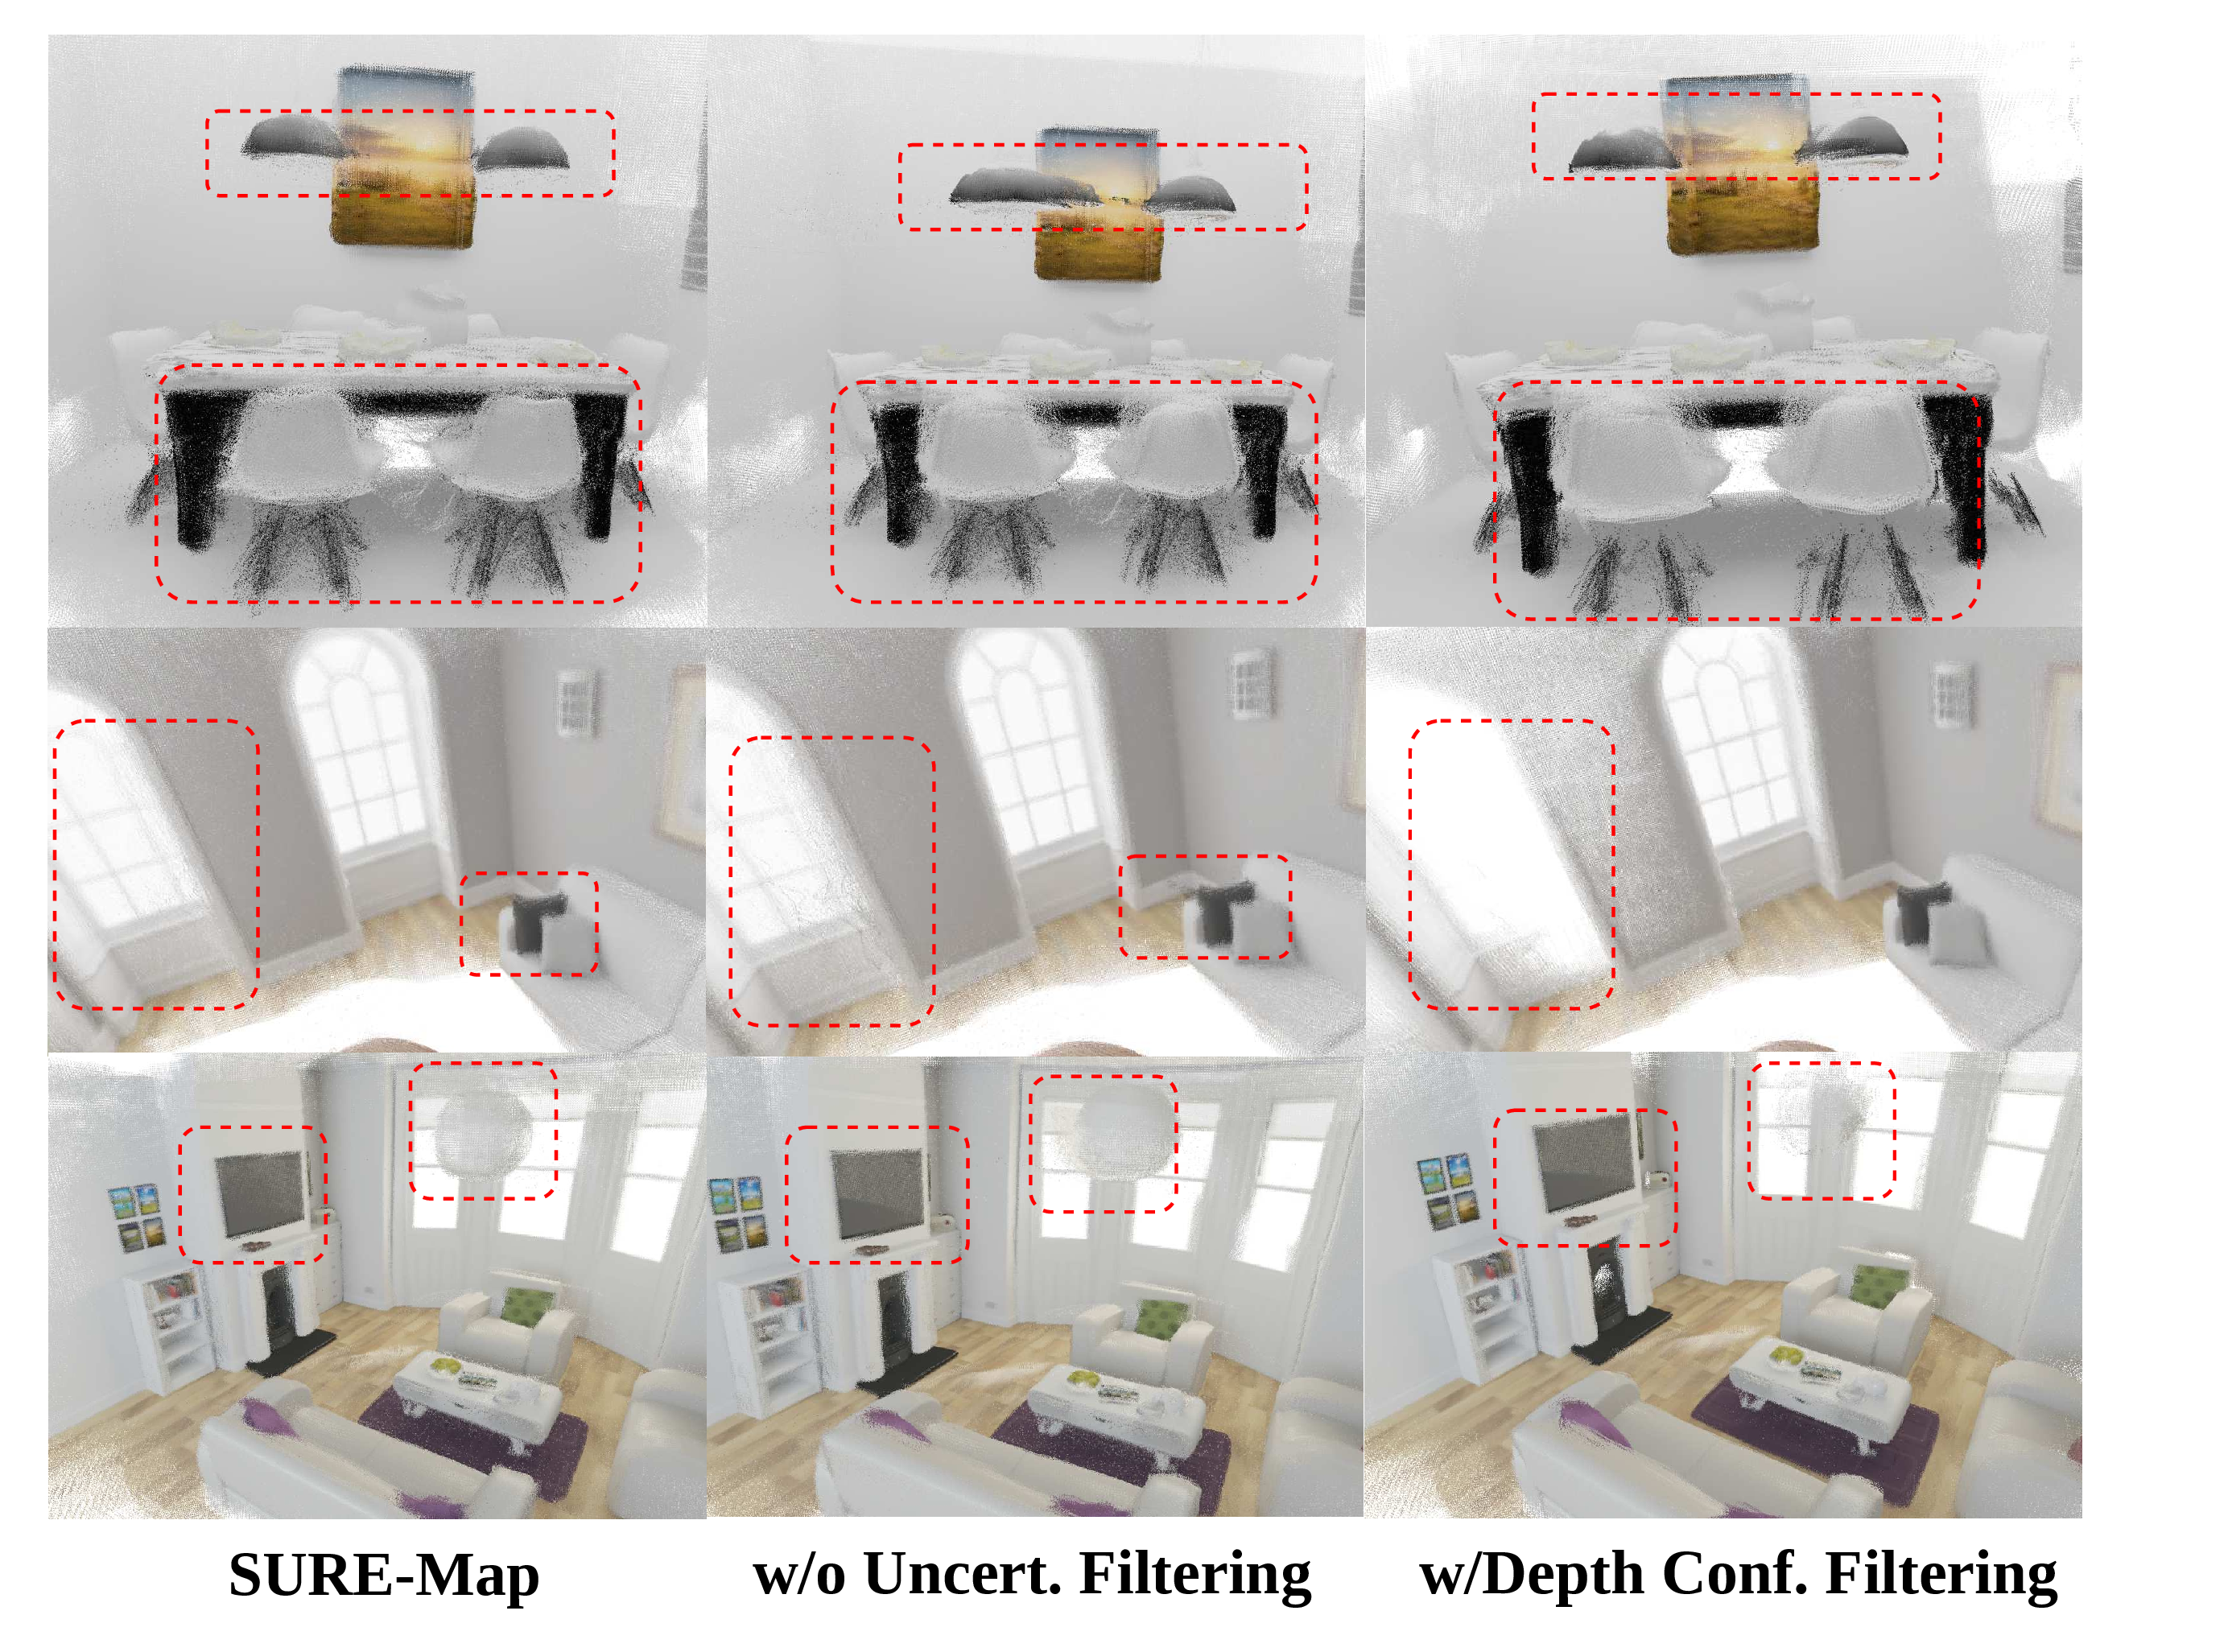
Learned geometric uncertainty rejects unreliable points while preserving valid scene structures.
@misc{liu2026suremapselfcorrectingstreaminggeometric,
  title         = {SURE-Map: Self-Correcting Streaming Geometric Foundation Model},
  author        = {Mingkai Liu and Hao Zhao and Xingxing Zuo},
  year          = {2026},
  eprint        = {2609.15795},
  archivePrefix = {arXiv},
  primaryClass  = {cs.CV},
  url           = {https://arxiv.org/abs/2609.15795}
}